Teaching vehicles to see,
from city streets to forest trails.
I am a Project Assistant in the Vehicle Engineering and Autonomous Systems division of the
Department of Mechanical Engineering at Chalmers University
of Technology in Gothenburg.
In October 2026 I completed my PhD in Automotive Engineering for Intelligent Mobility at the
University of Bologna, supervised by Prof. Stefano Mattoccia at the Computer Vision Lab.
My research is about vision-based perception for autonomous systems: end-to-end driving, depth estimation with
event cameras, and metric visual odometry in natural environments, where GNSS is unreliable. During the PhD I
spent six months as a visiting researcher at Chalmers, in the same group I have now joined.
From 2020 to 2026 I was part of the UniBo Motorsport Driverless 1:10 team, which I led from
2024. We won the RoboRacer World Championship at ICRA 2025 and took 2nd and 3rd place at ICRA 2026.
Before the PhD I earned a BSc in Physics and an MSc in Artificial Intelligence at the University of
Bologna, spending the second year of the master's at NTNU in Trondheim.
News
- Nov 2026 Joined Chalmers University of Technology as a Project Assistant in the Vehicle Engineering and Autonomous Systems division.
- Oct 2026 Completed my PhD at the University of Bologna.
- Jul 2026 Extended abstract on route estimation from headcam video at the O-Conference 2026 in Gothenburg.
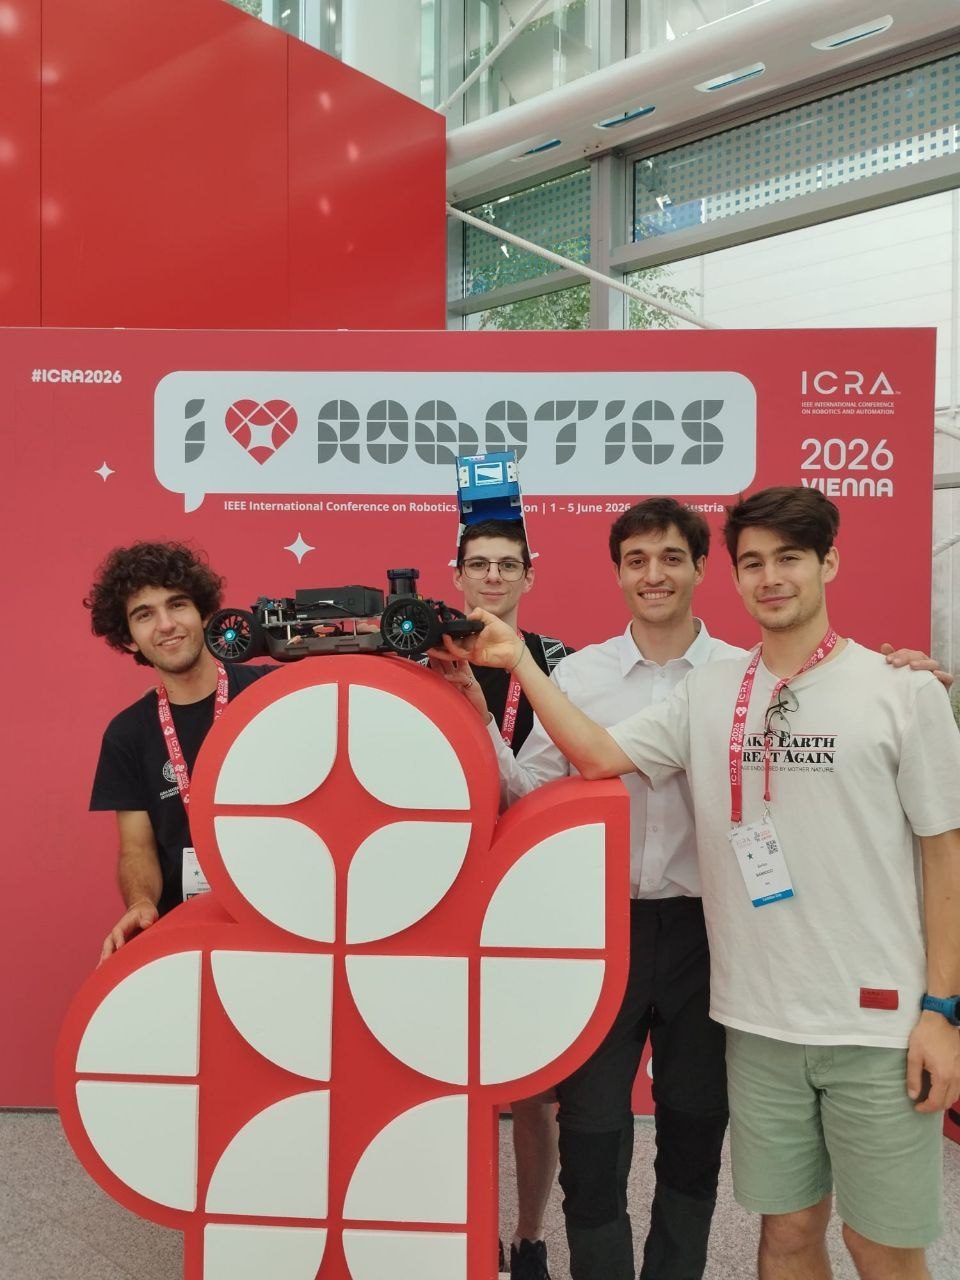
- Jun 2026 Our two cars finished 2nd and 3rd in the Master Cup of the RoboRacer World Championship at ICRA 2026 in Vienna, out of 29 teams.
- 2026 Towards Event-Based Stereo Depth Estimation at Millisecond Resolution published in IET Image Processing.
- Mar 2026 Started a six-month research period at Chalmers University of Technology, Gothenburg.
- Oct 2025 Depth AnyEvent presented at ICCV 2025 in Honolulu.
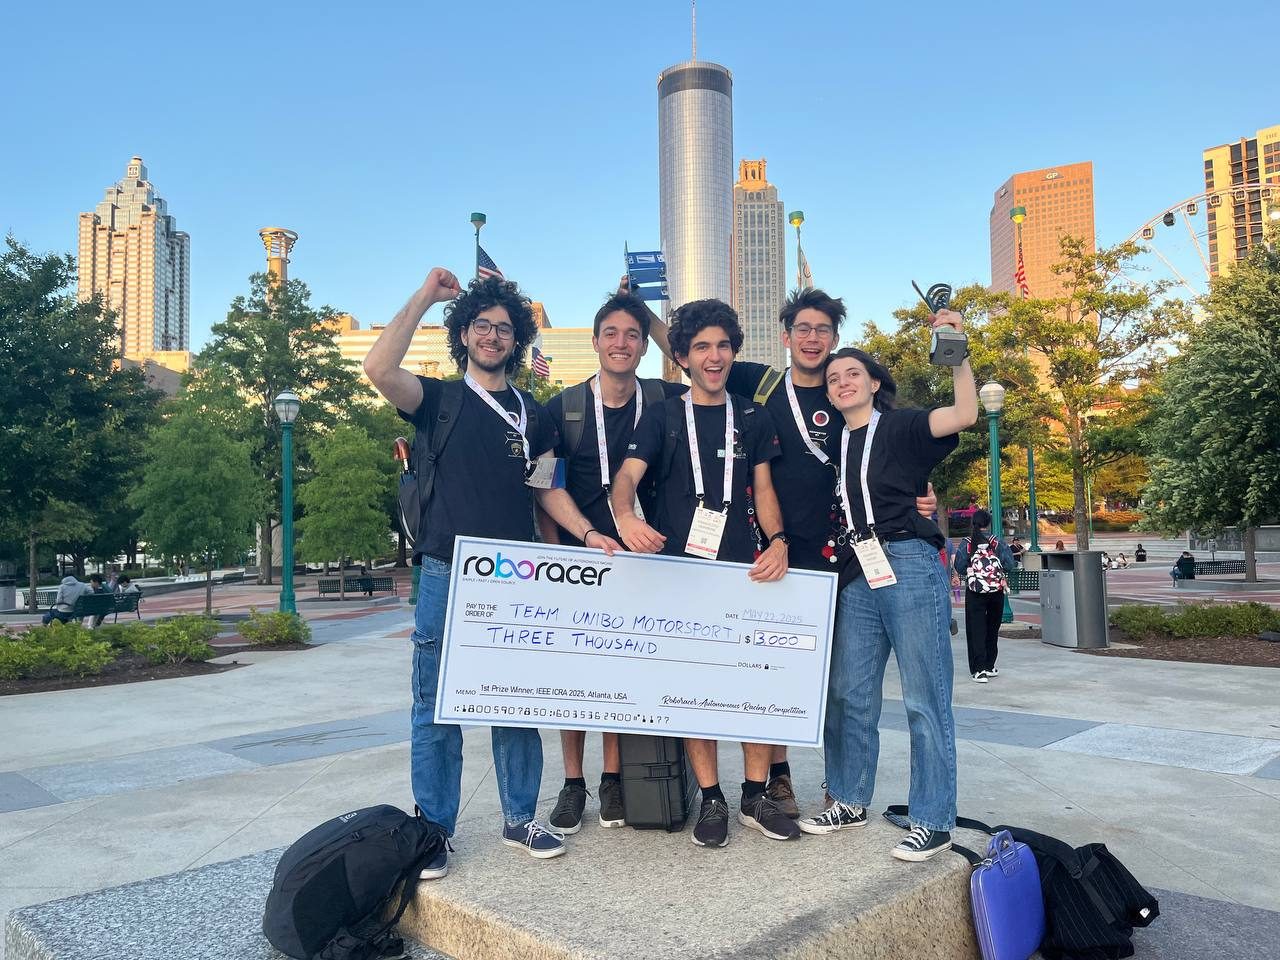
- May 2025 Drive with the Flow presented at ICRA 2025, and our team won the RoboRacer World Championship in Atlanta.
Publications
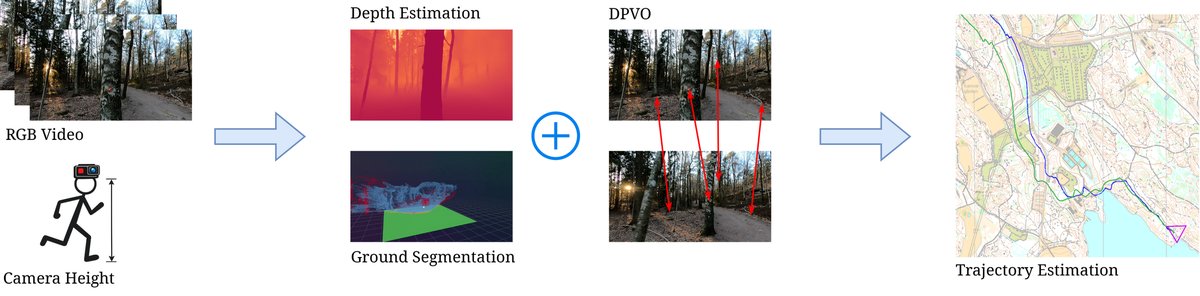
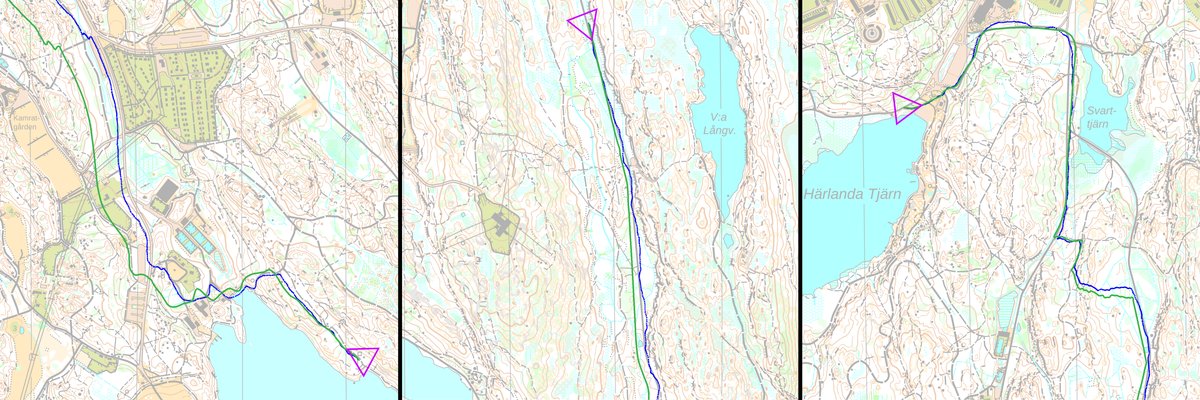
Metric Trajectory Estimation from First-Person Video of Runners in Forest Environments
Enrico Mannocci, Marco L. Della Vedova
Under submission
Recovers metric trajectories from monocular headcam video using the camera height above the ground as a cheap metric anchor, for forests where GNSS degrades under the canopy.
Towards Event-Based Stereo Depth Estimation at Millisecond Resolution
Enrico Mannocci, Luca Bartolomei, Fabio Tosi, Matteo Poggi, Stefano Mattoccia
IET Image Processing, 2026
MADNet-ε: a lightweight recurrent stereo network that predicts disparity from 10 ms event windows at about 145 FPS, plus ε-CARLA, a synthetic event-stereo dataset.
Route Estimation from Headcam Video in Orienteering
Enrico Mannocci
O-Conference 2026, Gothenburg (extended abstract)
Preliminary version of the forest trajectory work: estimating an orienteer's route from an RGB headcam video, the starting position and heading.
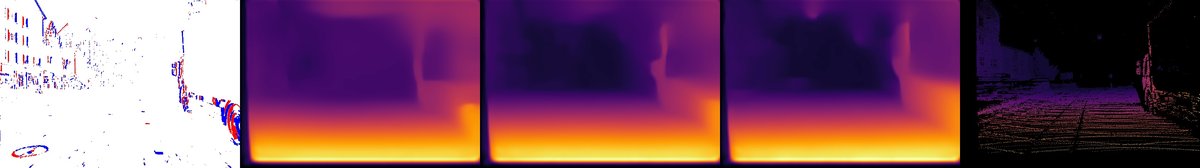
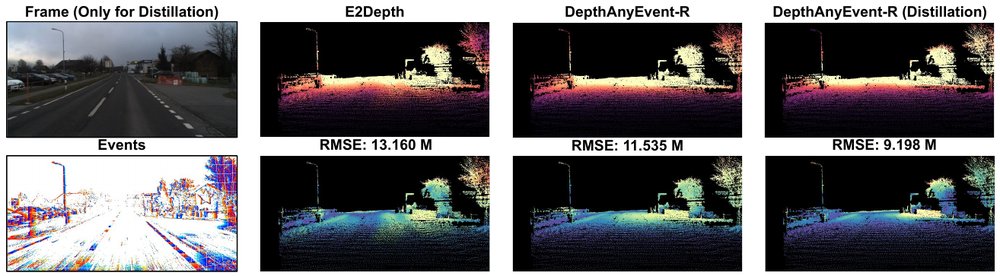
Depth AnyEvent: A Cross-Modal Distillation Paradigm for Event-Based Monocular Depth Estimation
Luca Bartolomei, Enrico Mannocci, Fabio Tosi, Matteo Poggi, Stefano Mattoccia
ICCV 2025, Honolulu
Distills dense proxy depth labels from a vision foundation model on RGB frames to train monocular depth networks on event cameras.
Drive with the Flow
Enrico Mannocci, Matteo Poggi, Stefano Mattoccia
ICRA 2025, Atlanta
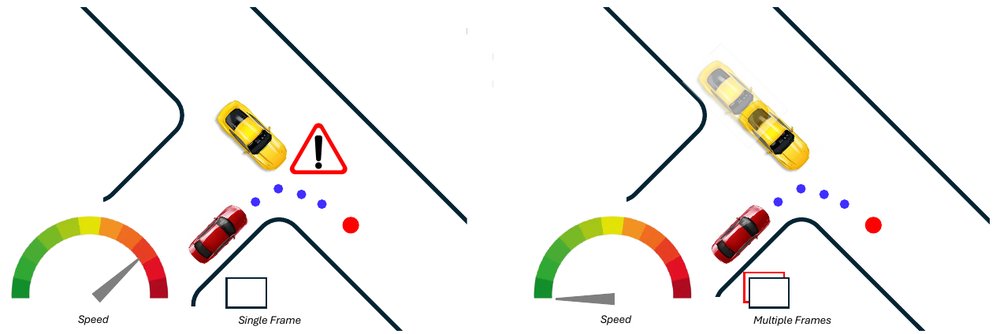
FlowFuser: adds optical flow as an auxiliary task to the perception module of an end-to-end driving model, improving collision avoidance in dense traffic in CARLA.
Steps forward to SST applications of slit-less multi-object spectroscopy with the SuperFOSC camera at the Loiano astronomical observatory
Matteo Lombini, Laura Schreiber, Andrea Bianco, Alberto Buzzoni, Albino Carbognani, Fausto Cortecchia, Michele Frangiamore, Roberto Di Luca, Emiliano Diolaiti, Silvia Galleti, Enrico Mannocci, Giovanna Stirpe
Proc. SPIE 12188, Advances in Optical and Mechanical Technologies for Telescopes and Instrumentation V, 2022
Theses
-
PhD: Vision-Based Perception for Autonomous Driving
University of Bologna, Automotive Engineering for Intelligent Mobility, 2023–2026. Supervisor: Prof. Stefano Mattoccia.
-
MSc: Sailing Boat Route Finder with Deep Reinforcement Learning
University of Bologna, Artificial Intelligence, 2023 (110/110 cum laude). Supervisor: Prof. Andrea Asperti.
A deep Q-network that plans sailing routes from satellite wind data, compared against the GPS tracks of the Vendée Globe 2020/21 skippers.
-
BSc: Studio della modalità spettroscopica dello strumento SuperFOSC per il telescopio Cassini
Study of the spectroscopic mode of the SuperFOSC instrument for the Cassini telescope
University of Bologna, Physics, 2021 (110/110). Supervisor: Prof. Matteo Lombini.
Compares spectroscopic configurations for the instrument used for space debris surveillance at the Loiano observatory.
Autonomous Racing
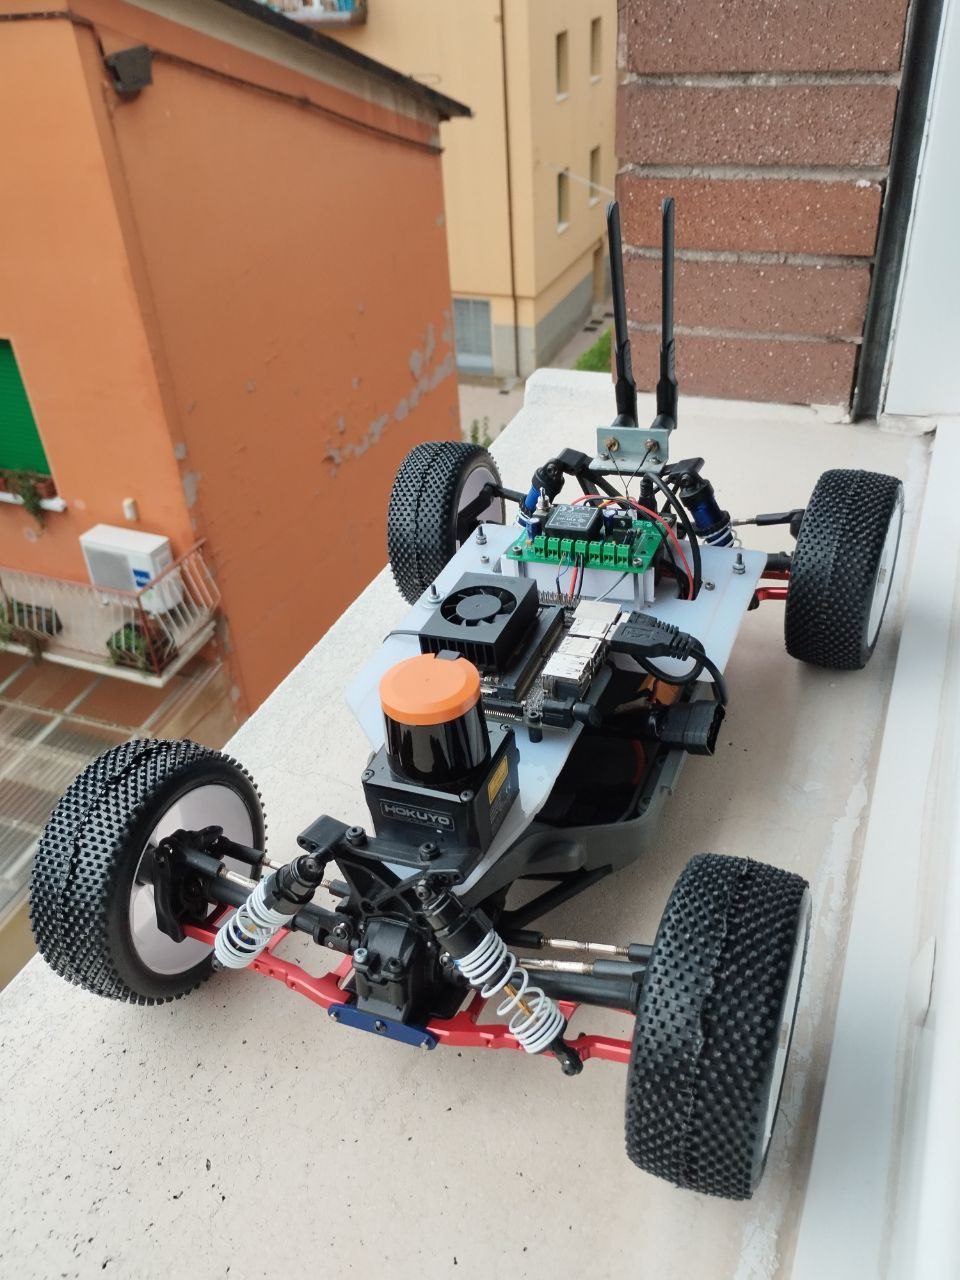
I joined the UniBo Motorsport Driverless 1:10 team in 2020 and led it from 2024 to 2026, coordinating
about twenty bachelor's and master's students. We build and program 1:10 scale autonomous cars for the
RoboRacer competitions held at ICRA: open practice to map the track, time trials,
and a head-to-head tournament where detecting and overtaking the opponent is essential.
- 1st place, RoboRacer World Championship, ICRA 2025, Atlanta
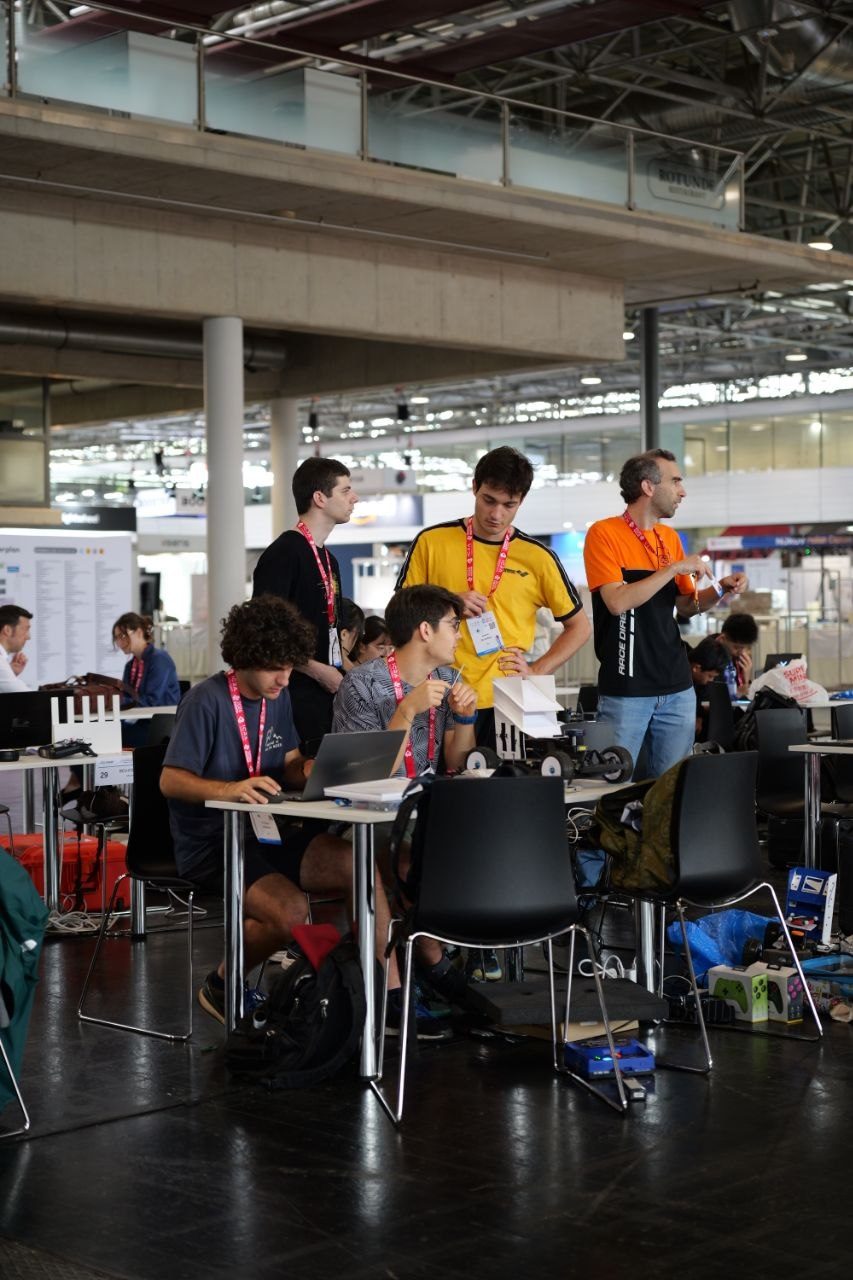
- 2nd and 3rd place, Master Cup, RoboRacer World Championship, ICRA 2026, Vienna (29 teams)
For the 2026 season I replaced our pure-pursuit and Frenet overtaking stack with a single nonlinear
Model Predictive Controller (CasADi + IPOPT): it follows the raceline and avoids walls and opponents in one
optimisation, so overtaking emerges from the same cost function.
I also ported our algorithms to Rust in AuRoRus, an open-source
autonomous racing stack for RoboRacer / F1TENTH cars with simulator, SLAM, planning and a web GUI.
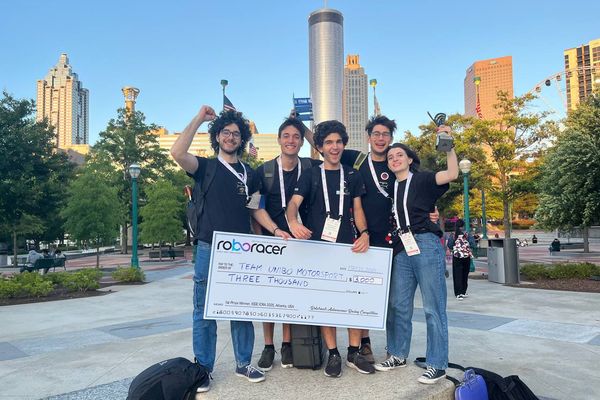
World champions, Atlanta 2025
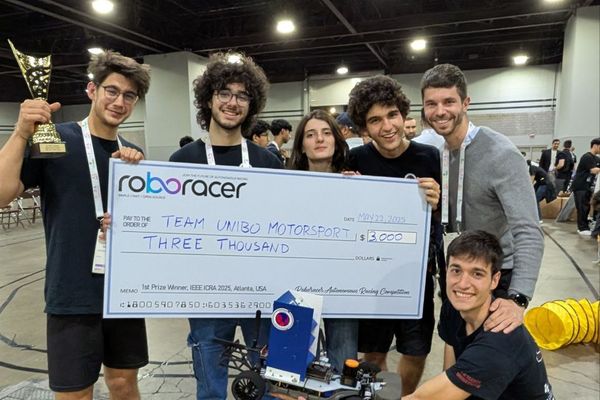
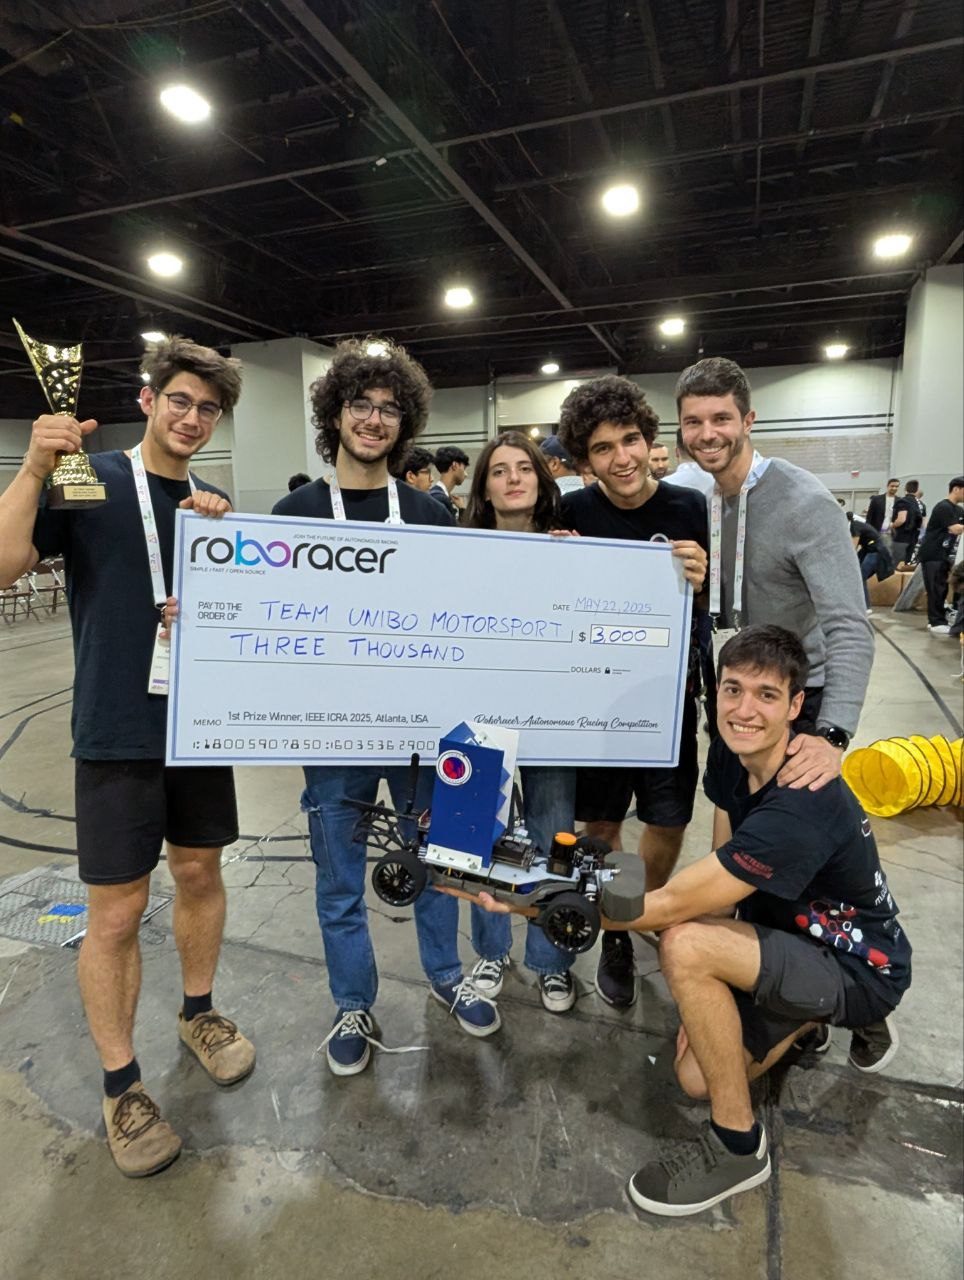
The team with the winning car, Atlanta 2025
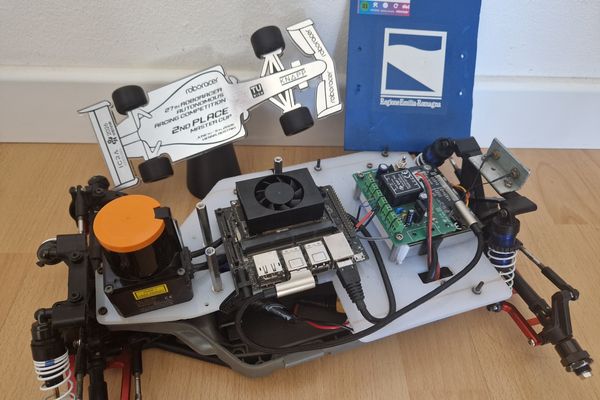
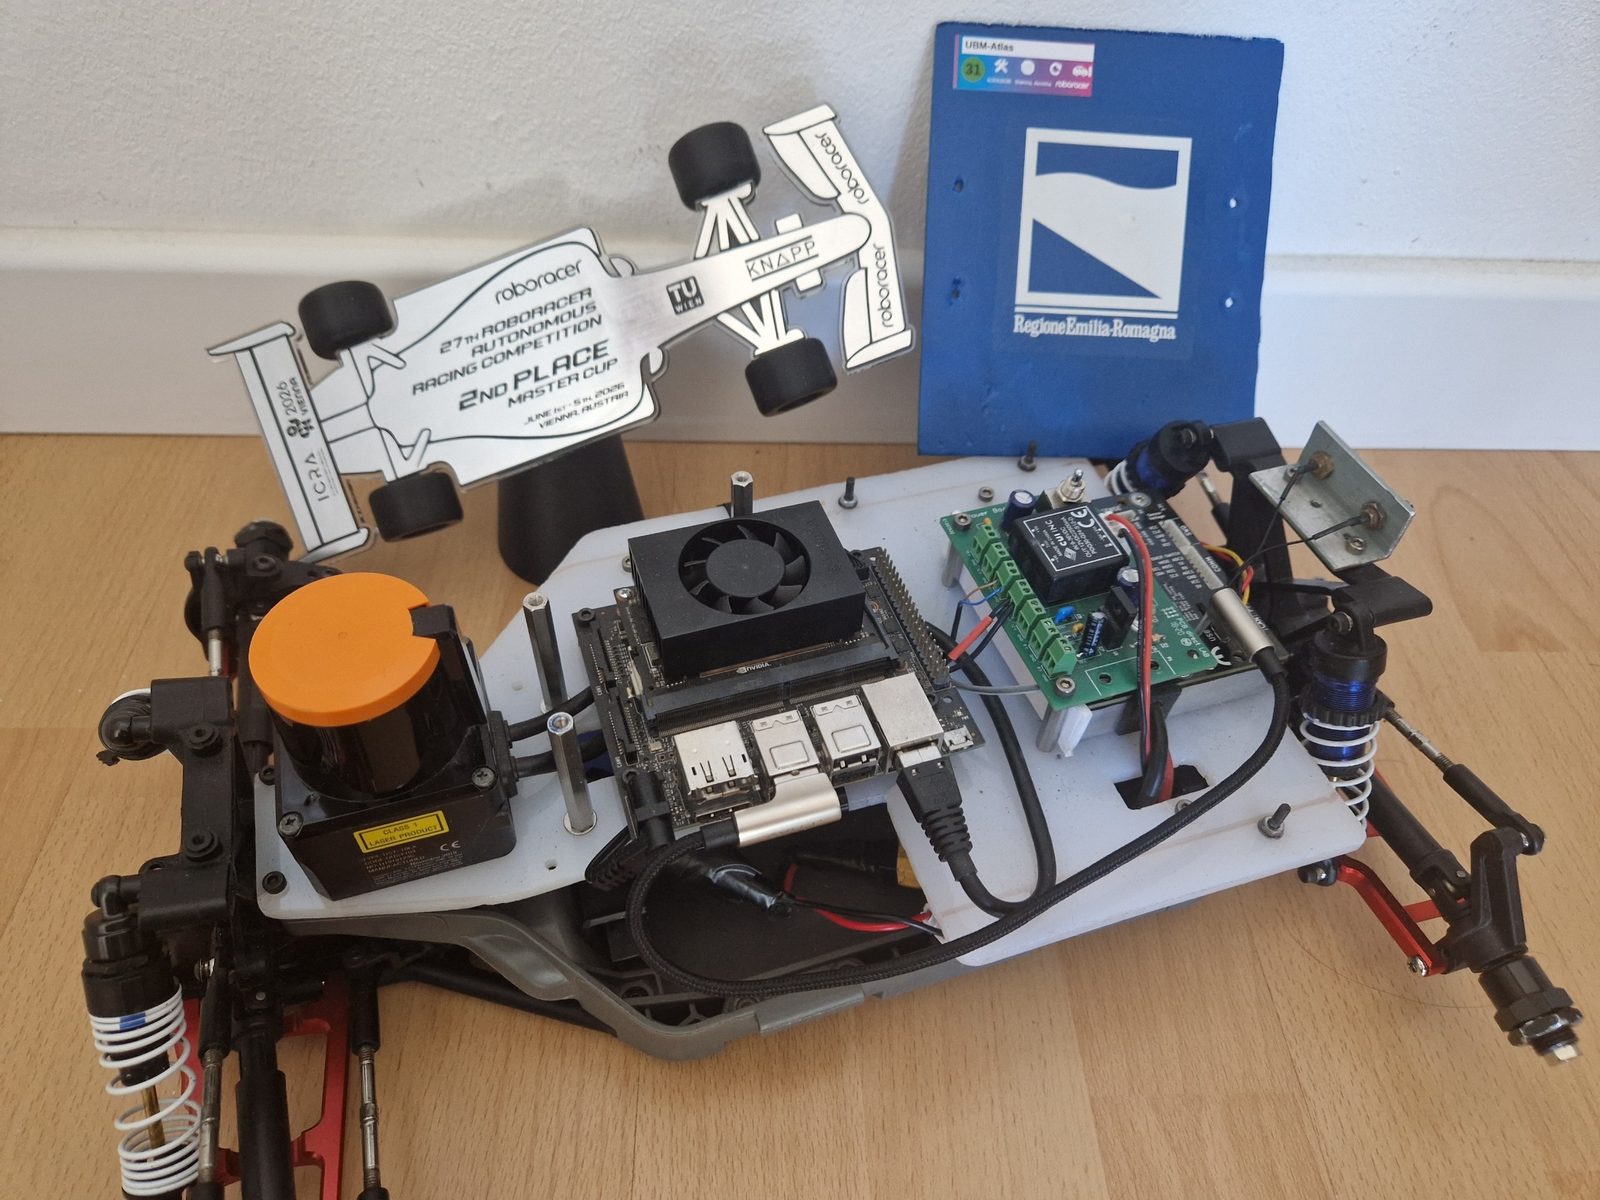
Our car with the Vienna trophy
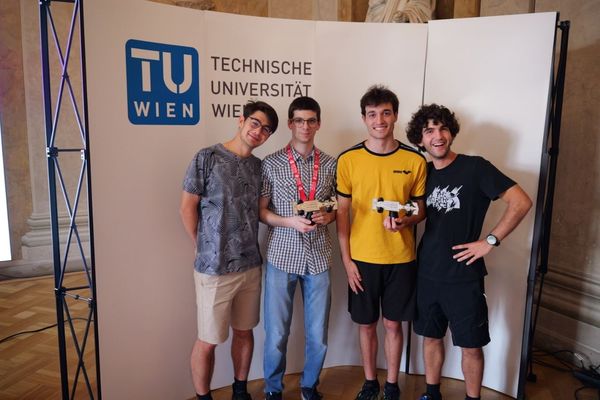
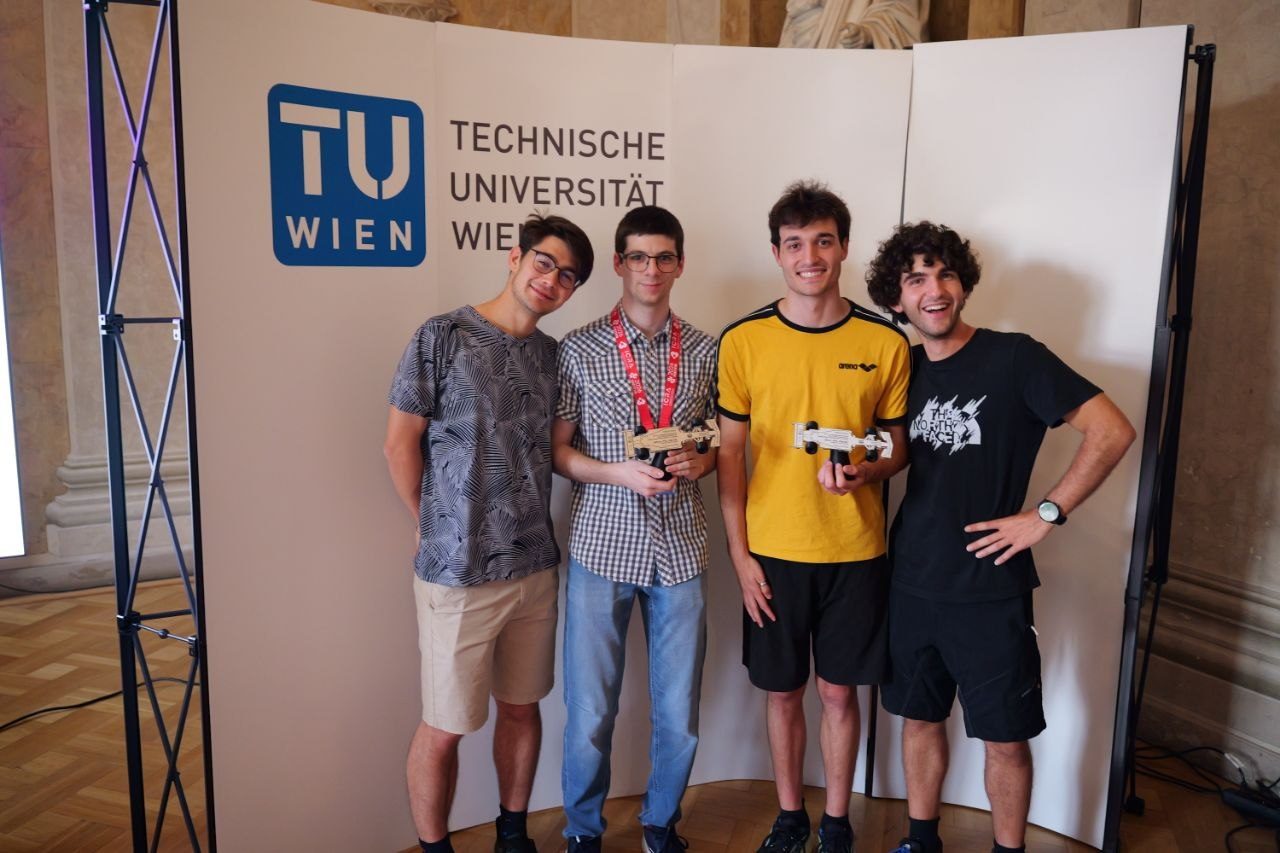
Prize-giving ceremony, Vienna 2026
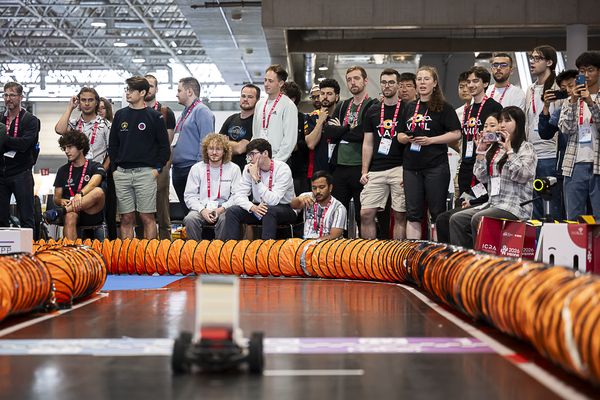
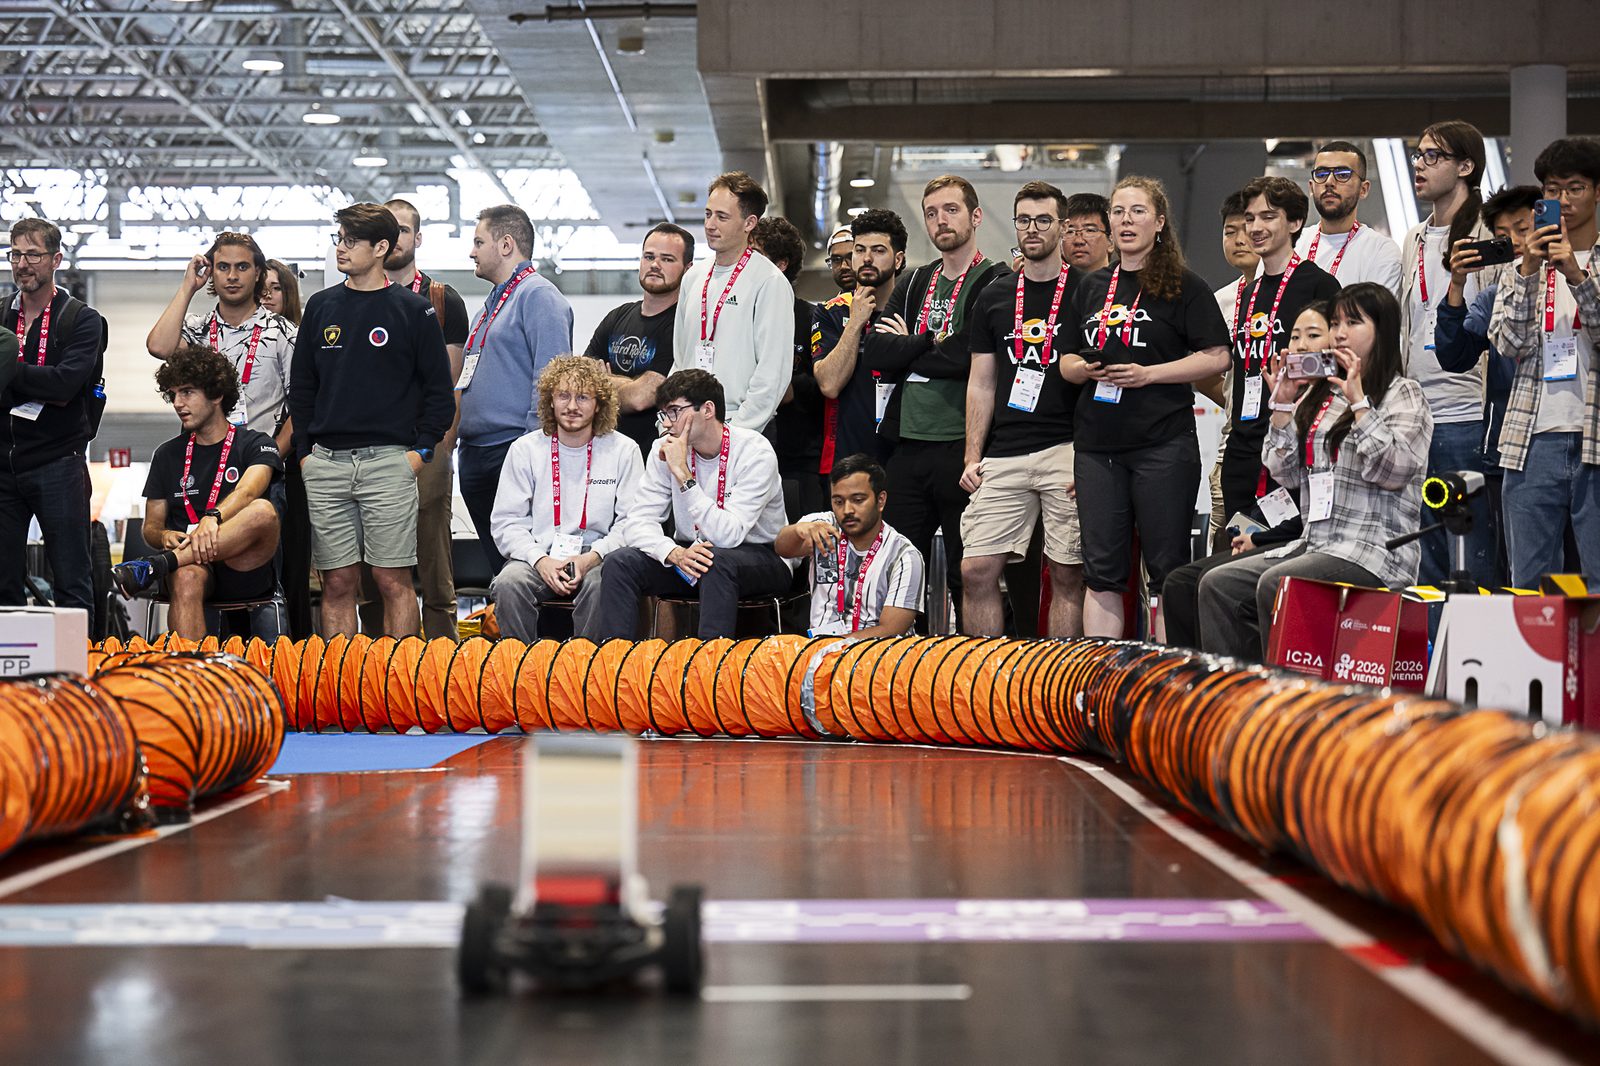
Head-to-head race, Vienna 2026
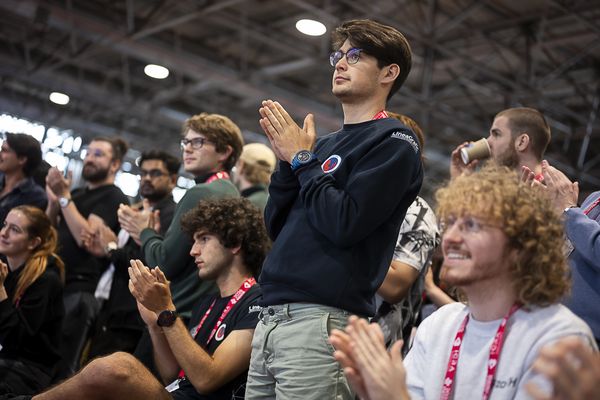
Watching the race, Vienna 2026
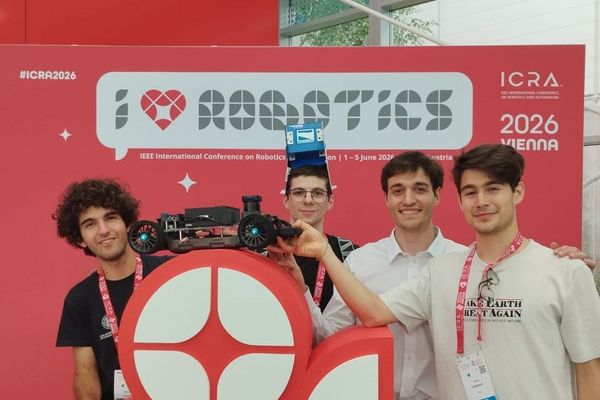
After the race, ICRA 2026
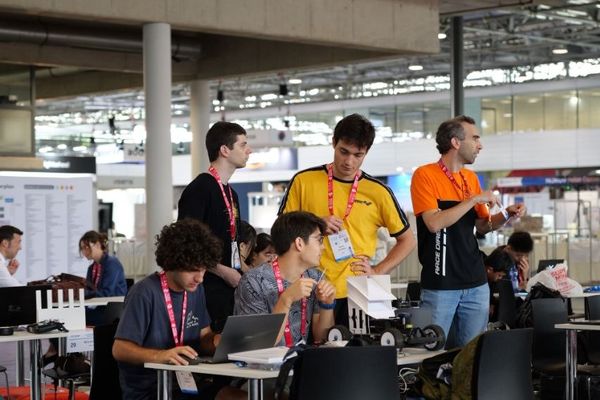
The team at work, Vienna 2026
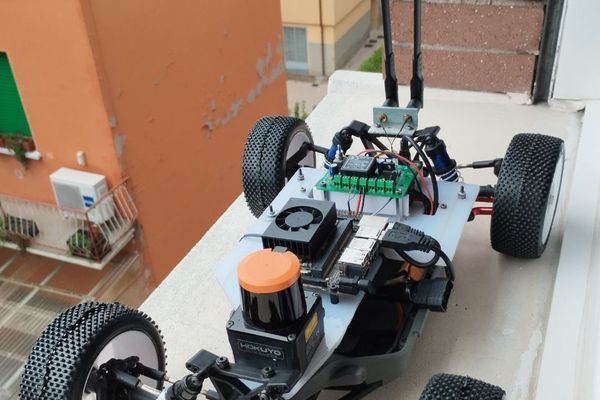
One of our 1:10 cars
Projects
Autonomous RoboRacer Rust: an autonomous racing stack in Rust for RoboRacer (F1TENTH) cars, with simulator, SLAM, race-line planning, opponent detection, Frenet overtaking, MPC and a web GUI. Code on GitHub.
Map utilities in Rust for orienteering: renders OpenOrienteering Mapper maps to images from the command line, with tools to benchmark the output against a reference renderer.
Code of my master's thesis: deep reinforcement learning for sailing boat route planning on real wind data.